
Position: Benchmarks for Vision–Language Models in Urban Perception Should Be Reliability-Aware and Negotiated
Year: 2026
ICML · Peer-reviewed position paper
Mushkani, R. (2026). Position: Benchmarks for Vision–Language Models in Urban Perception Should Be Reliability-Aware and Negotiated. Proceedings of the 43rd International Conference on Machine Learning, PMLR 306, 171558–171571.
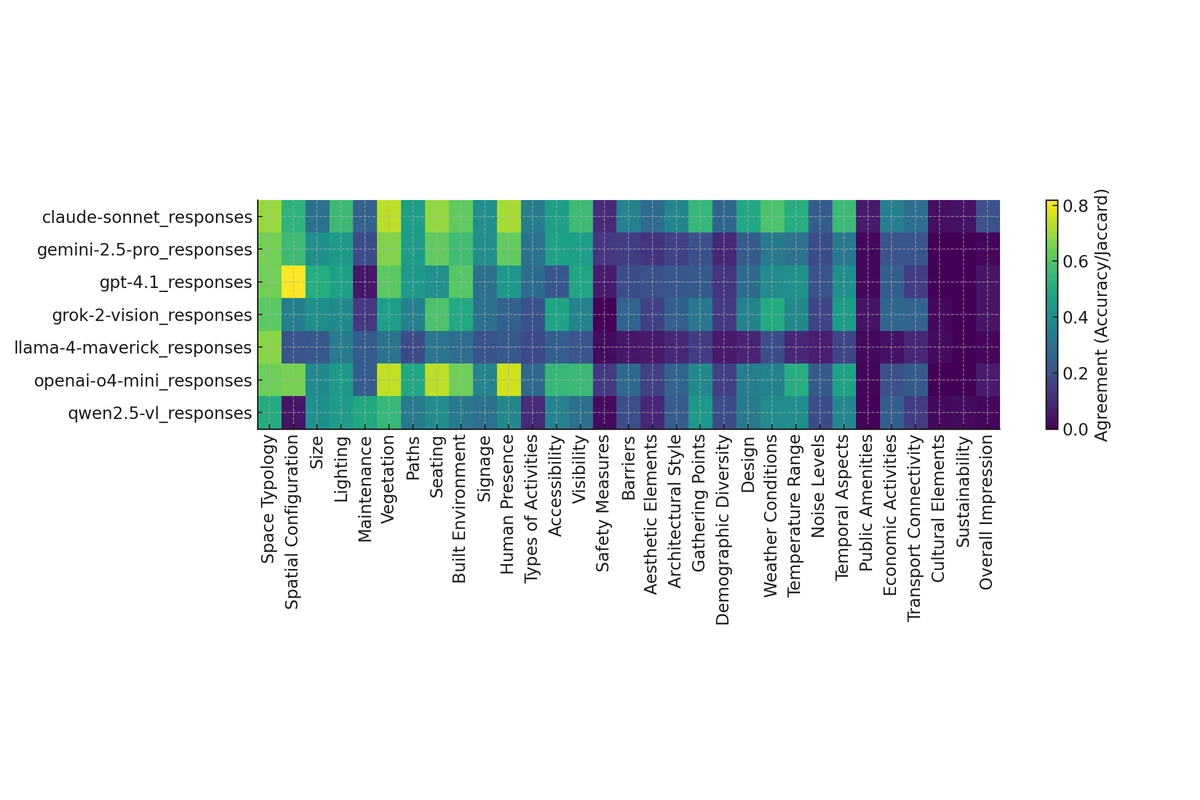
Using Montréal street scenes evaluated by community participants and vision–language models, this paper argues that disagreement and abstention carry information. Benchmark categories and scoring rules should remain open to negotiation when their results inform urban governance.